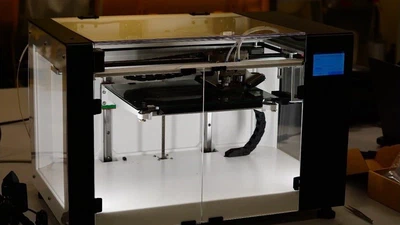
Anisoprint Composer A4
A composite 3D printer for complex thermoplastic parts reinforced with continuous carbon-fiber filaments.
Browse the research platforms used by MAAL and shared facilities across HKUST. Each entry identifies ownership, intended use, and available specifications or training material.
Access to shared facilities is subject to the responsible unit’s booking, training, and safety requirements.
A composite 3D printer for complex thermoplastic parts reinforced with continuous carbon-fiber filaments.
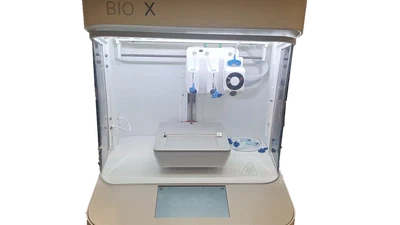
A multi-head bioprinting platform used in tissue engineering, drug discovery, toxicity studies, and advanced 3D cell culture.
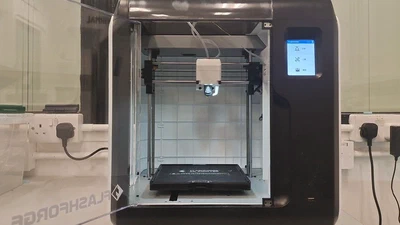
A compact FDM printer for rapid PLA prototypes, with a nominal dimensional accuracy of ±0.2 mm.
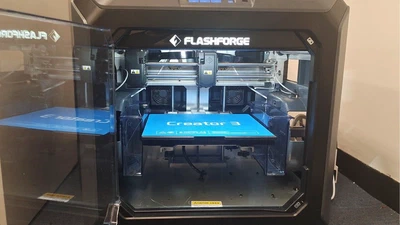
A dual-extrusion FDM platform for precise prototypes and small production runs, with a high-precision mechanical structure and network connectivity.
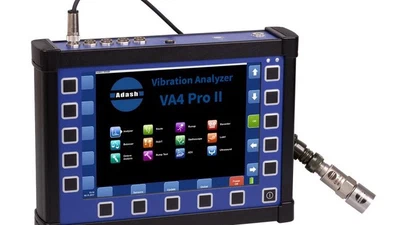
A portable vibration analyzer controlled from a computer through the Virtual Unit software for configurable measurement and diagnosis.
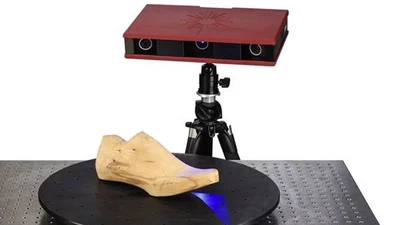
A non-contact scanning system for reverse engineering, rapid prototyping, dimensional inspection, and production quality control.
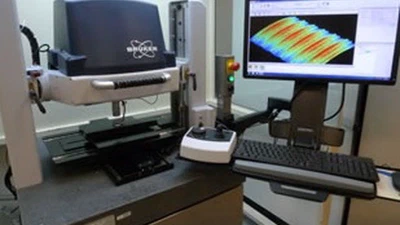
A non-contact areal surface-characterization system for large samples in aerospace, automotive, biomedical, and precision-machining applications.
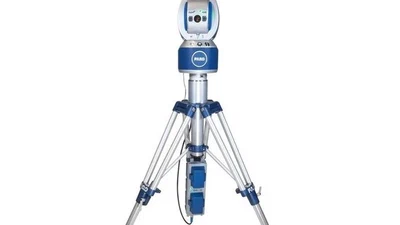
A large-volume coordinate-measurement instrument that locates optical targets with accuracy on the order of 0.025 mm over several metres.
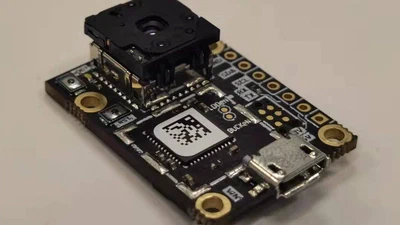
A compact thermal-imaging module used to monitor extruded-filament temperature and provide process feedback in additive manufacturing.
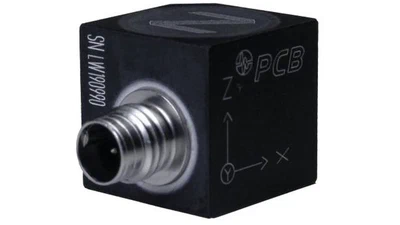
A triaxial accelerometer used for vibration measurements and dynamic-system identification.
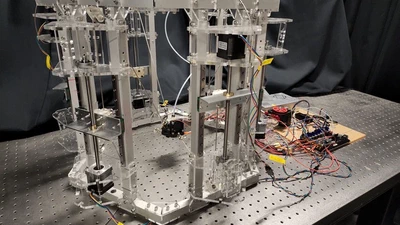
A six-cable additive-manufacturing platform that provides three-axis translation together with pitch and roll control.
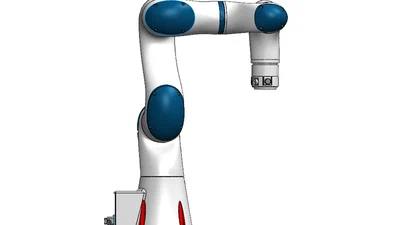
A collaborative manipulator used for kinematic modeling and real-time position, velocity, and force control under disturbance.
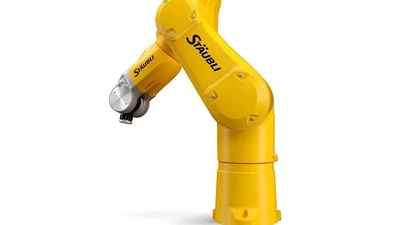
A six-axis industrial robot used to study flexible-link and joint dynamics, end-effector errors, trajectory generation, and vibration compensation.
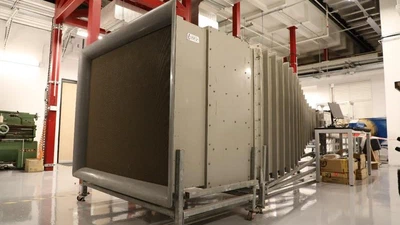
An open-return wind tunnel with a 4.5 kW motor and a reconfigurable test section for aerodynamic and aeroelastic experiments.
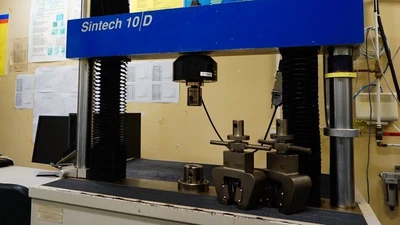
A universal test frame for tensile and compressive characterization of materials and printed specimens.